This page was generated from the component’s built-in descriptions. An in-depth article has not been written for it yet.
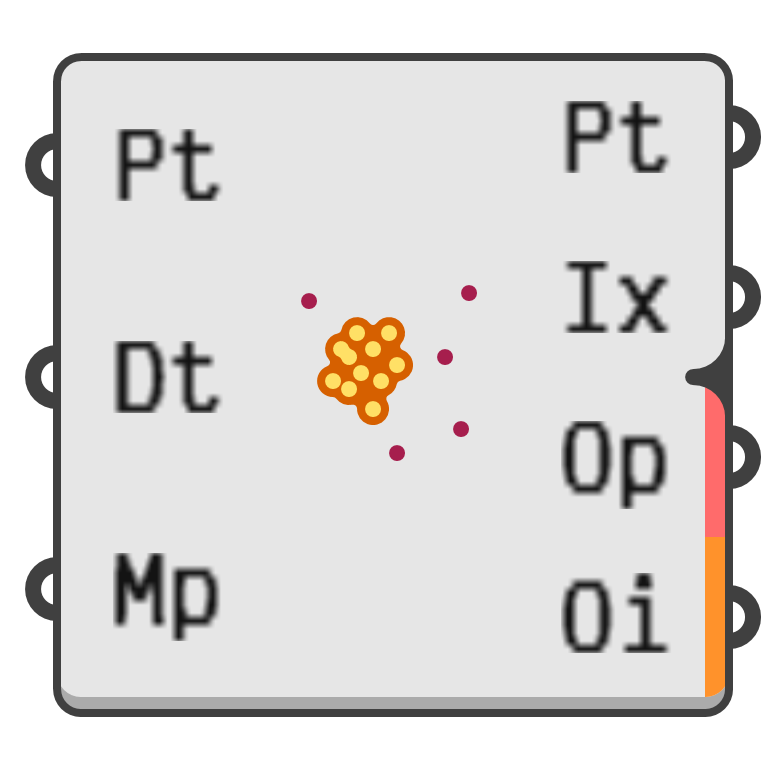
Cluster densely-packed points into groups, leaving sparse outliers out as noise.
Input parameters:
- Pt → Points to group.
- Dt → Neighbourhood radius used to count how many points sit close to each candidate.
- Mp → Minimum number of points (including the point itself) inside the neighbourhood radius for a point to anchor a group. Points with fewer neighbours are dropped as noise.
Output parameters:
- Pt → Points in each group, one branch per group.
- Ix → Indices of points in each group (relative to the input cloud), one branch per group.
- Op → Points classified as noise — those without enough neighbours to anchor or join a group.
- Oi → Indices of the noise points relative to the input cloud.